SpaceTeens student project · computer vision
AI agricultural robot
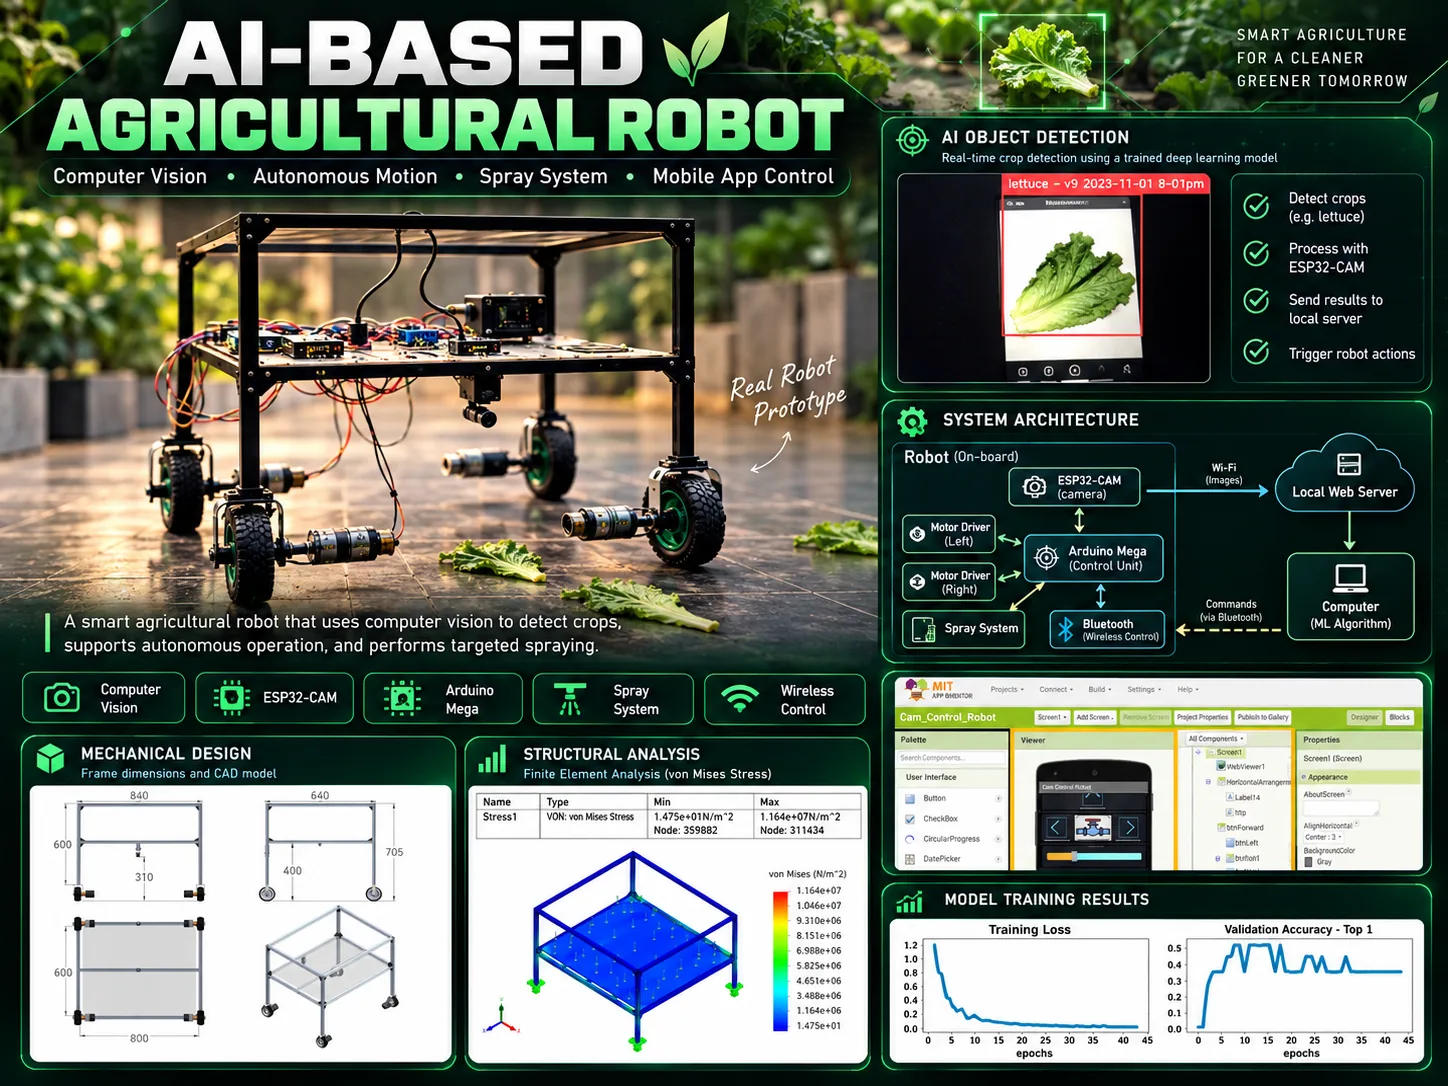
A farm robot that uses a camera and a trained model to recognise plants, moves on its own and sprays where needed.
What I did: mechanical, electronics, firmware, interface
The problem
The students wanted a robot that tells plants apart by camera instead of spraying everything.
What I built
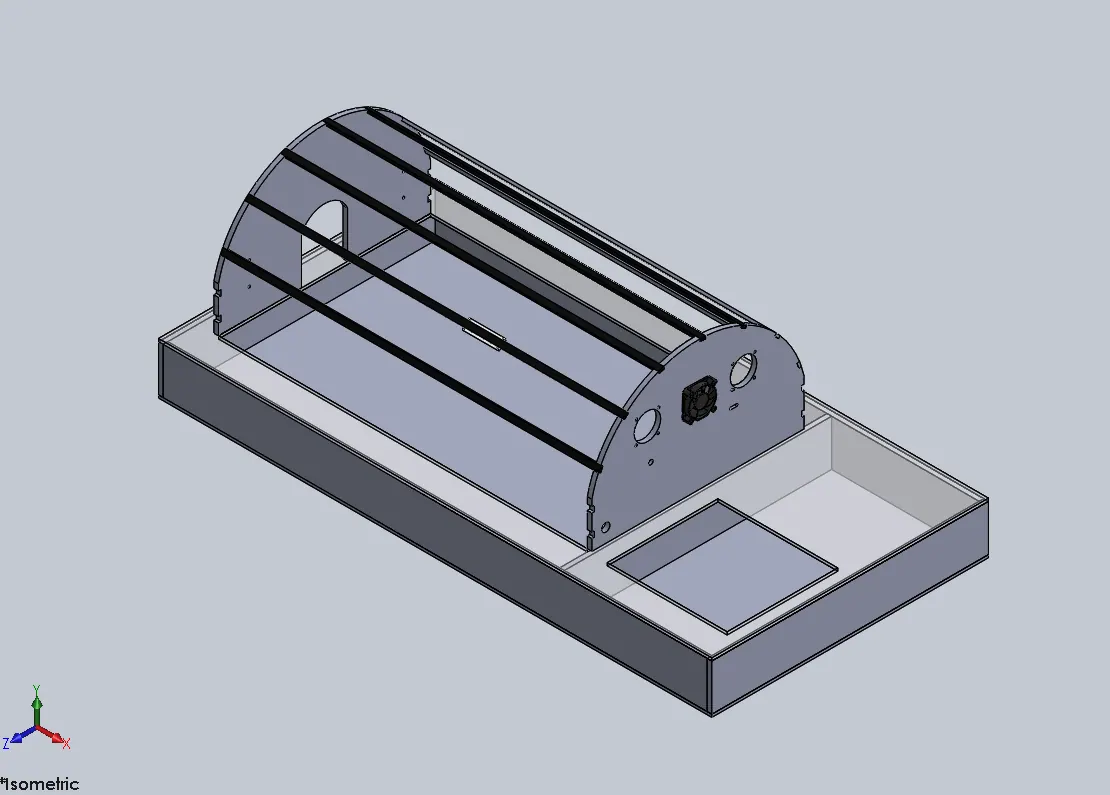
- A frame designed in CAD and checked with a structural analysis.
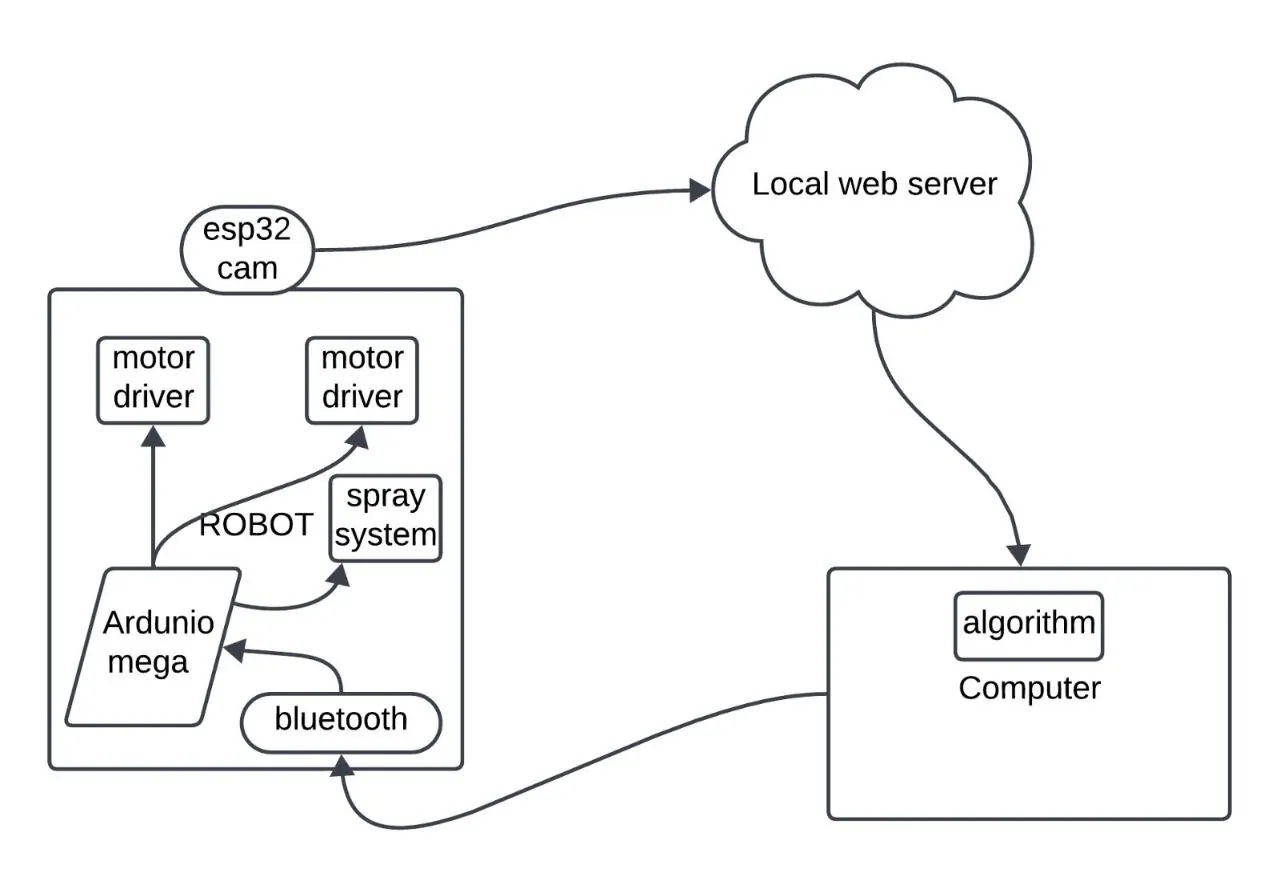
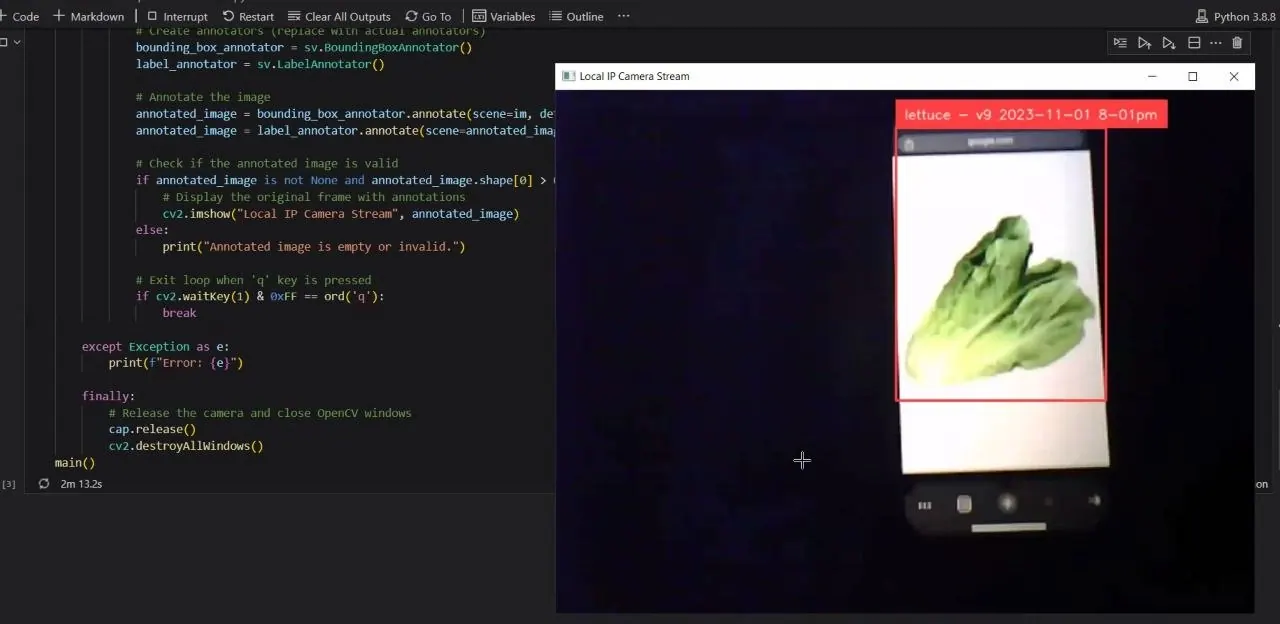
- An ESP32-CAM running a trained model to detect plants.
- Autonomous movement, a spray system and a mobile app for control.
Result
A working robot that detects plants and acts on what it sees.